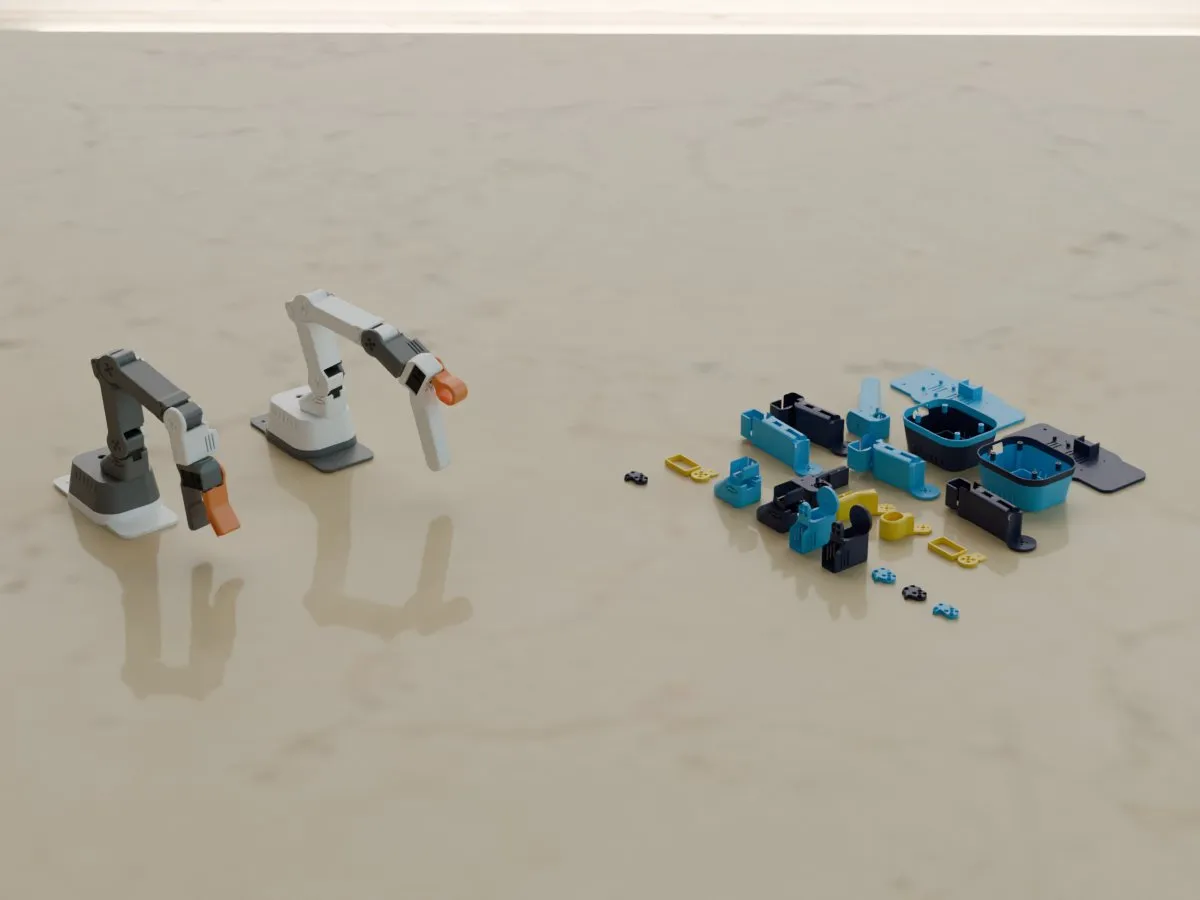
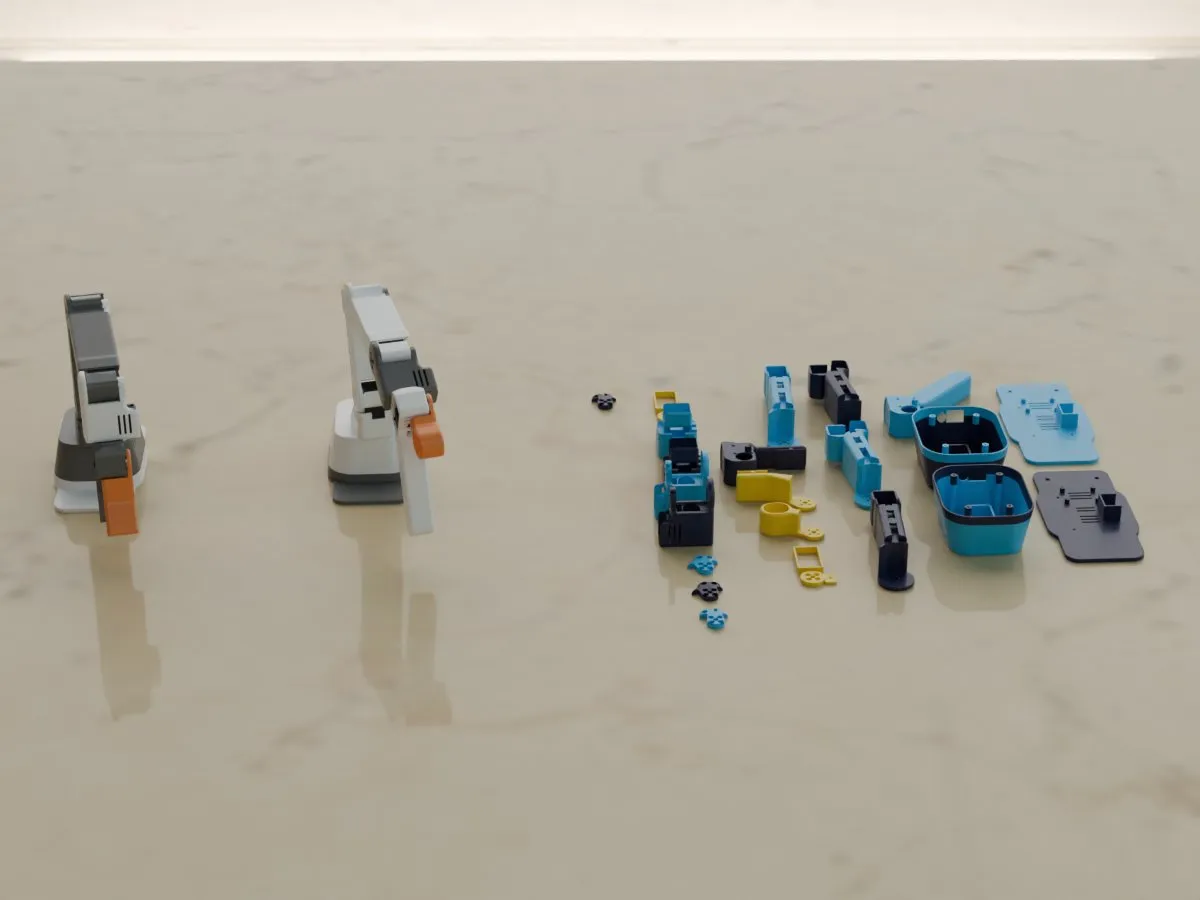
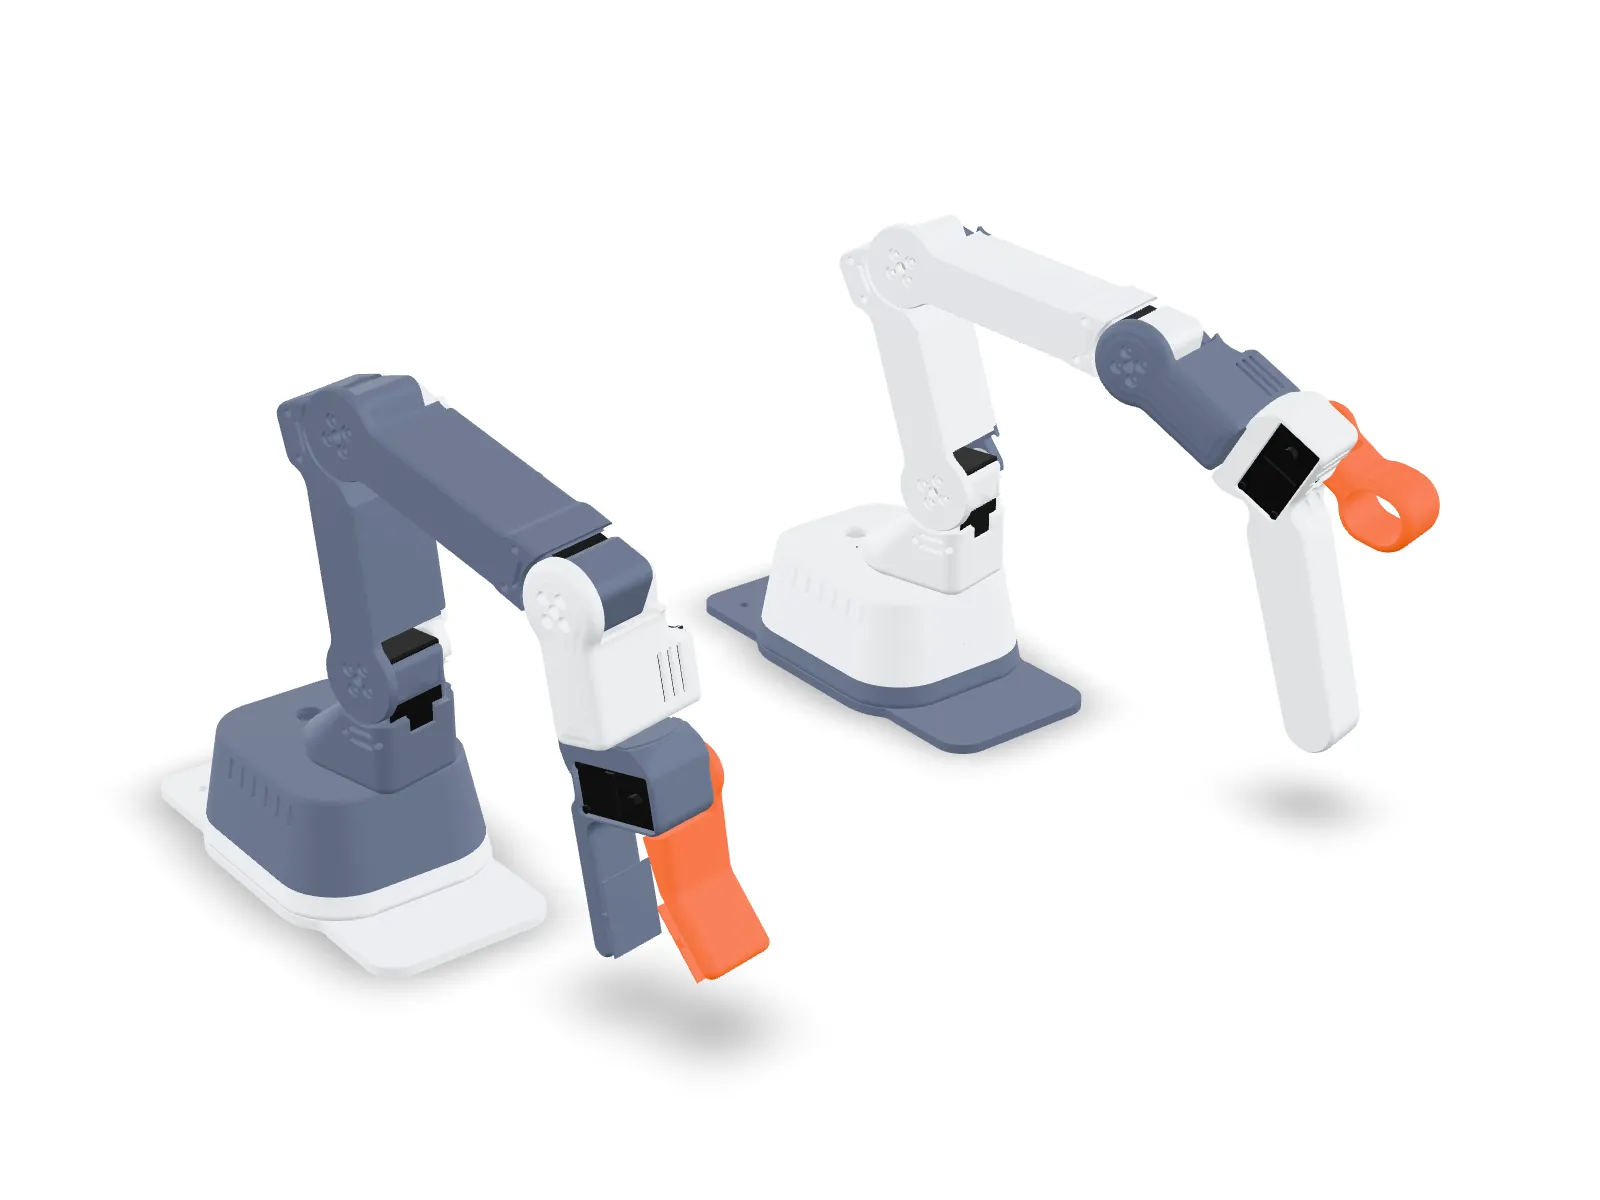
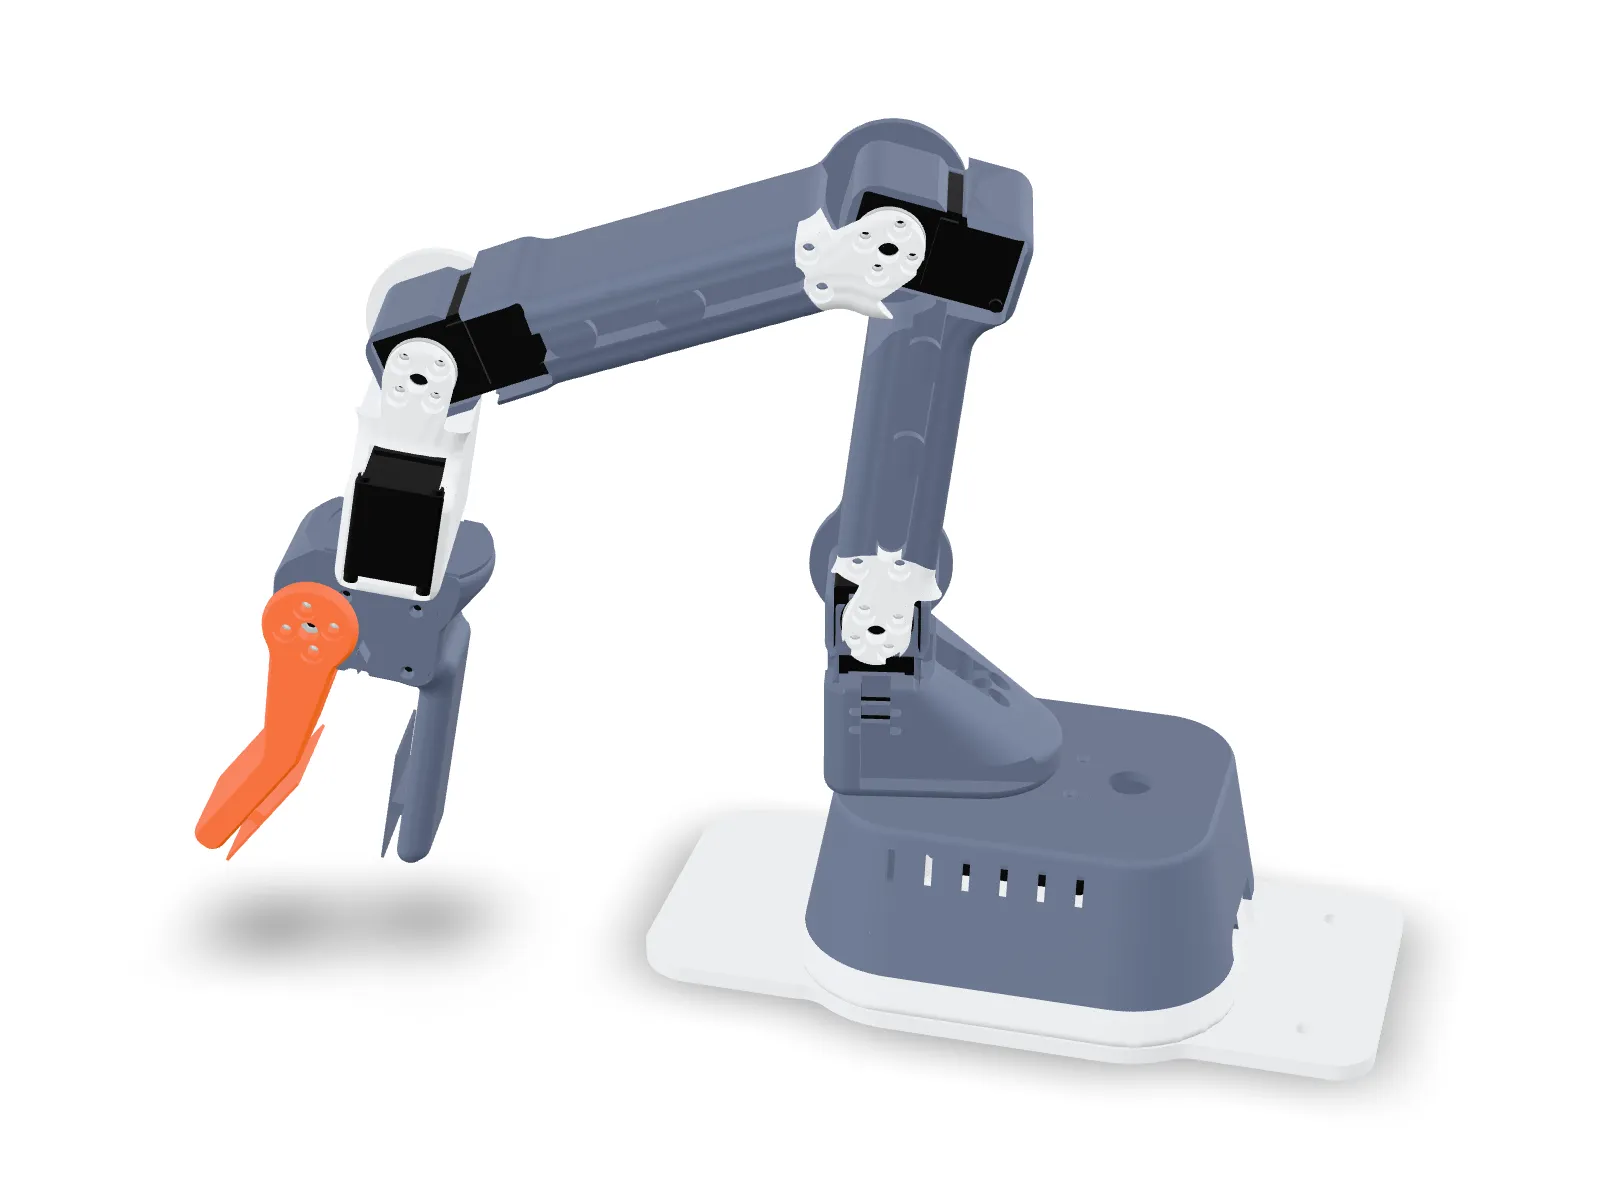
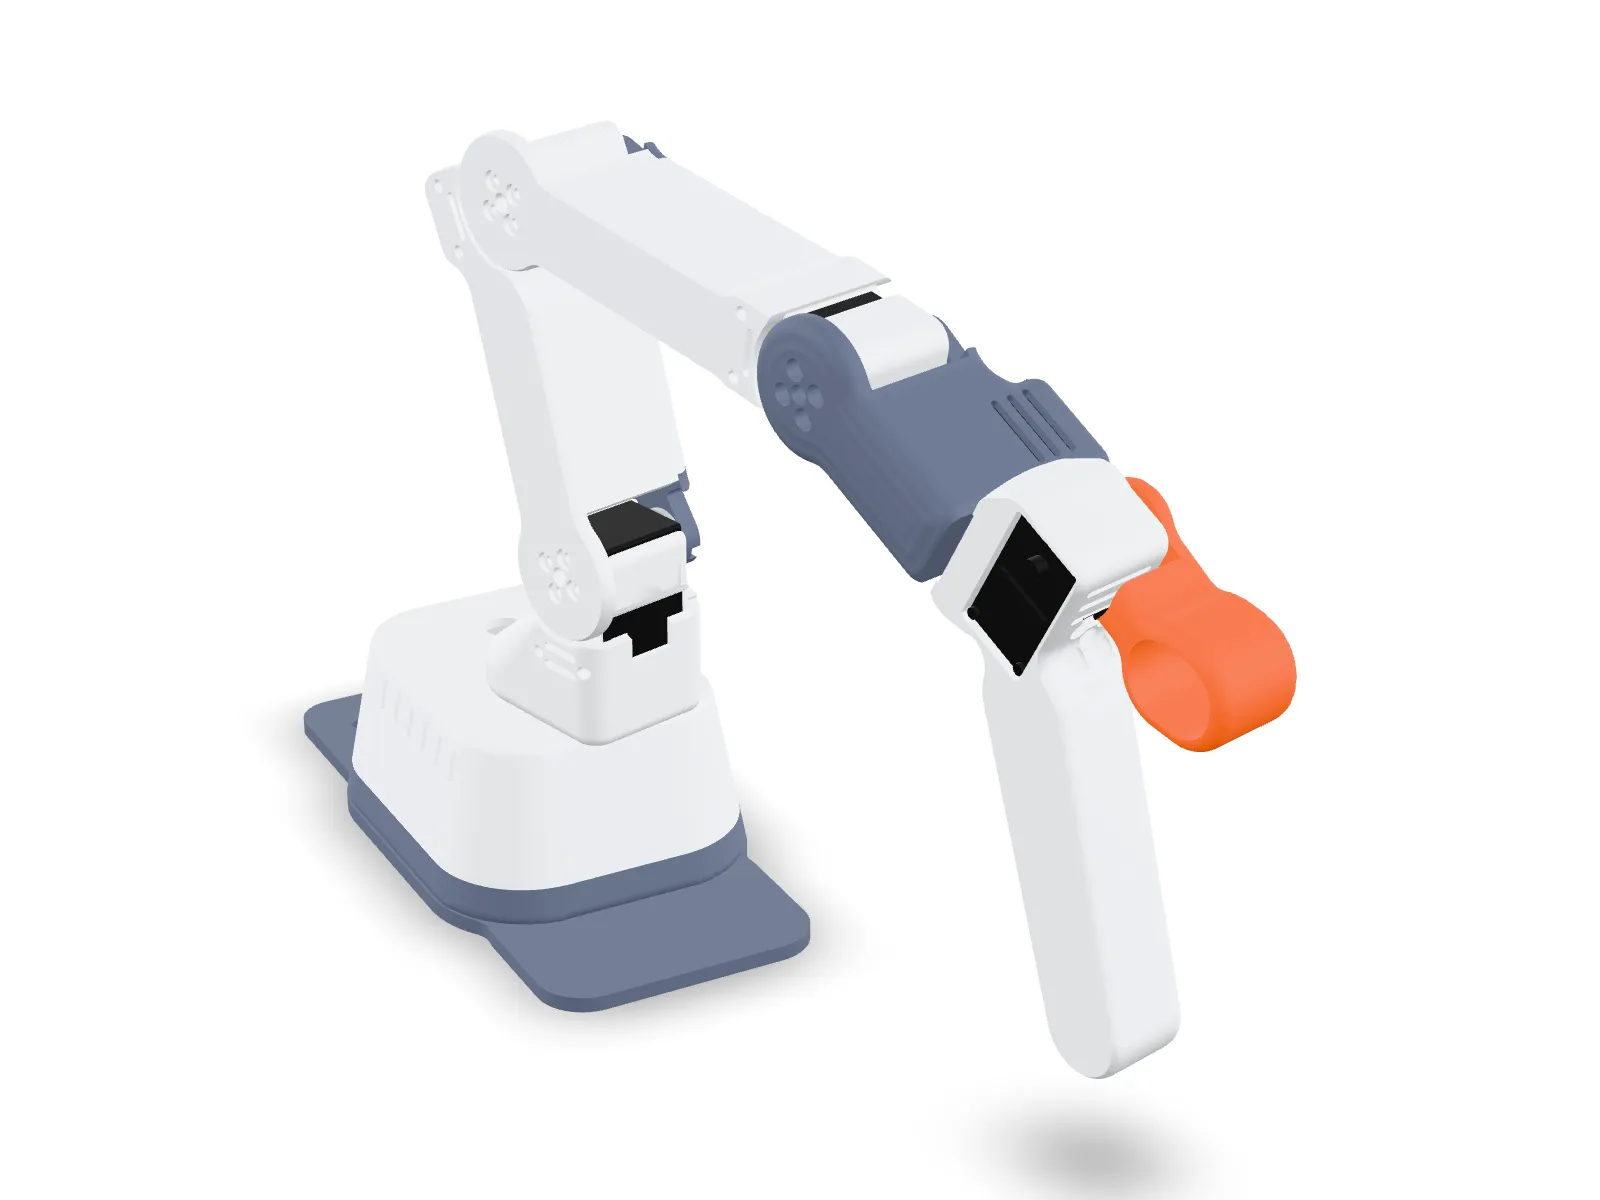
Robot arm pair, follower and leader
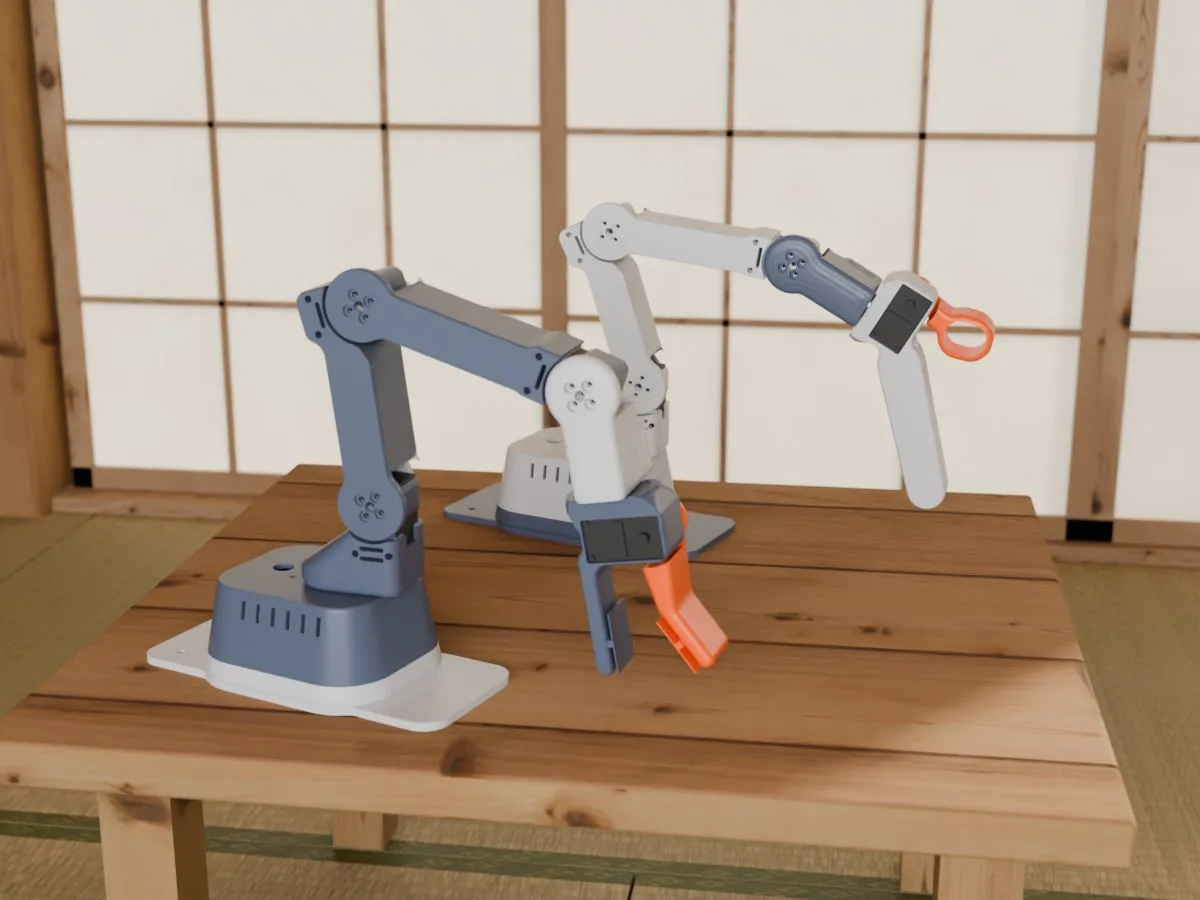
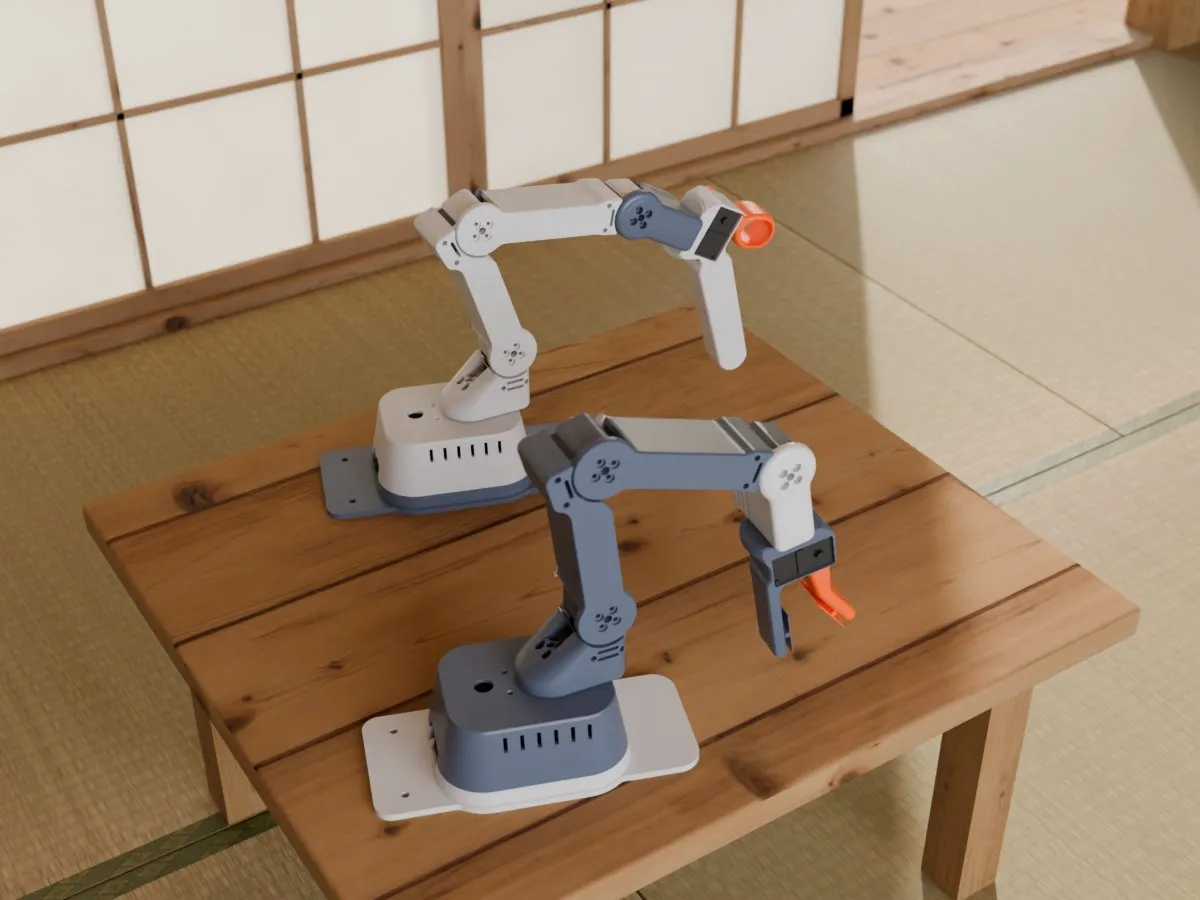
Two desktop arms for teaching tasks by hand. I move the leader and the follower copies it.
- Reach from the pan axis
- 440 mm
- Payload with the forearm level, and reaching down to the table (kg), my estimate
- 0.06 and 0.31
- Print time
- 30.0 h on 8 plates
- Filament
- 1034.3 g
Colourway
- Blue grey main
- Light gray second
- Orange accent
About the design
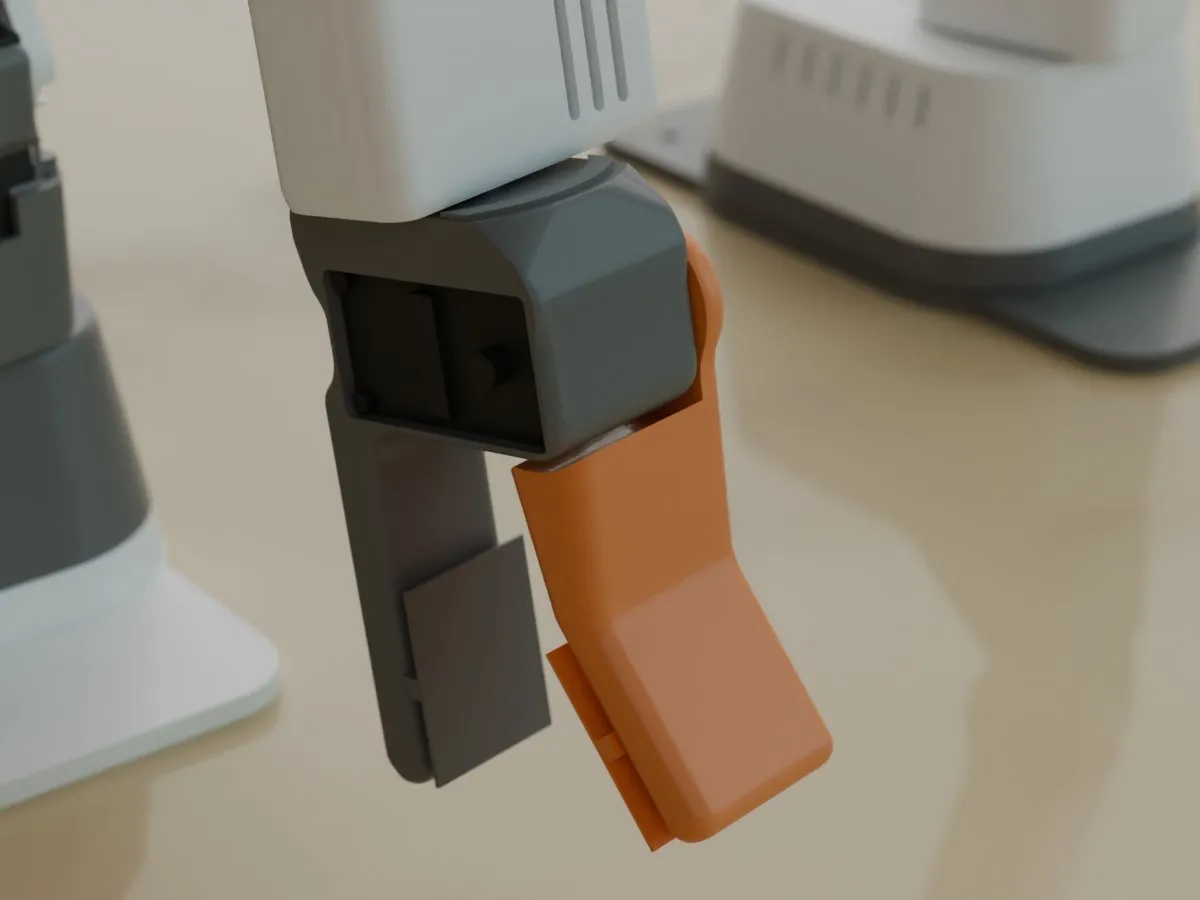
This is my pair of desktop robot arms for teleoperation and for teaching a robot new tasks. I hold the leader by its grip and trigger, and the follower copies every move with its gripper. I record those moves as demonstrations, and LeRobot learns from them to do the task alone. The joints sit exactly where SO-101's do, so its calibration and its software work unchanged. Every printed part is my own design. Each arm has six serial bus servos. The first four each get their own power lead from a hub in the base, and the two at the wrist branch from the fourth through short leads. So the far joints keep full power when the arm works hard. Air flows past every servo through vents, and no servo is shut in. The follower's fingers carry springy pads and close against a stop before they can jam. Leads run in grooves along the arm with spare length at every joint, and round caps cover the elbow and shoulder joints. A small gauge checks the servo and horn fits before the rest is printed. Both arms print in PLA, and only the two long links need a little support under one face.
What you can change
- Clearances of the servo pockets, the horns and the turning parts
- Wall, cheek and boss sizes and the curves of the shells
- The fingers' spring pads and the closing stop
- The leader's grip and trigger loop
- The base, its board and its power hub
- The lead grooves and the slack kept at each joint
- The supply voltage
Specifications
- Reach from the pan axis
- 440 mm
- Payload with the forearm level, and reaching down to the table (kg), my estimate
- 0.06 and 0.31
- Lead slack kept at pan / lift / elbow / wrist / roll
- 74 / 29 / 28 / 25 / 32 mm
- Servos
- 12 x Feetech STS3215, 6 per arm, in SO-101's gear ratios
- Supply
- 6 V, 5 A per arm
- Joint travel, lift / elbow / wrist (deg)
- -100 to 100 / -97 to 72 / -95 to 95
- Gripper opening (deg)
- -2 to 100
- Give of each finger pad
- 3 mm
- Grip at the closing stop with nothing held (N), my estimate
- 6.5
- Printed parts, follower and leader (g), my estimate
- 442 and 487
Printing
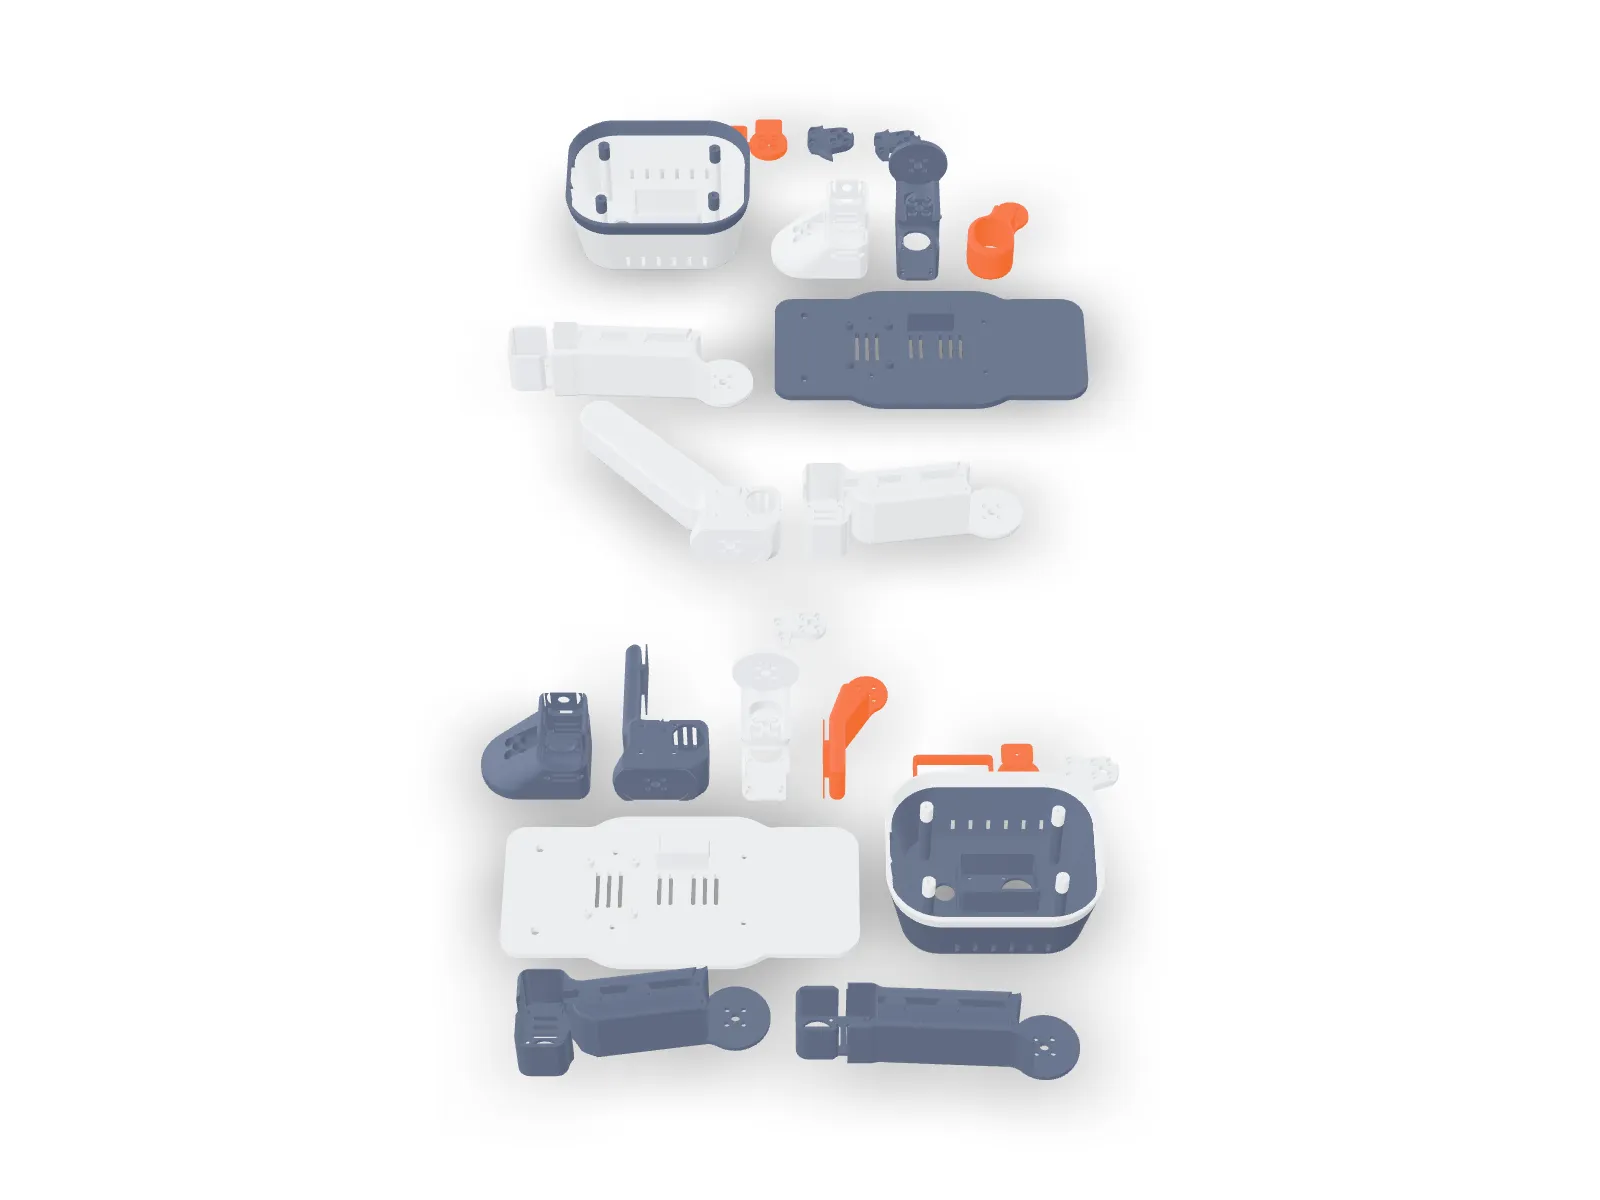
| Project | Plates | Hours | Grams |
|---|---|---|---|
| Follower, PLA Basic | 4 | 14.6 | 502.3 |
| Leader, PLA Basic | 4 | 15.4 | 532.0 |
| Total | 8 | 30.0 | 1034.3 |
Times and weights come from slicing the model at 0.20 mm layers. Each figure is rounded on its own.
In the room
Credits and licence
The kinematics and the layout are those of SO-101 by TheRobotStudio and Hugging Face (https://github.com/TheRobotStudio/SO-ARM100), licensed Apache-2.0 (https://www.apache.org/licenses/LICENSE-2.0). Its URDF gives every joint's place, axis and range and every servo's place, and I kept them exactly so the pair works with LeRobot. The servo mounting holes come from the servo model published with SO-101. Every printed part is my own design, and no SO-101 part's geometry is used.
- Licence
- All rights reserved