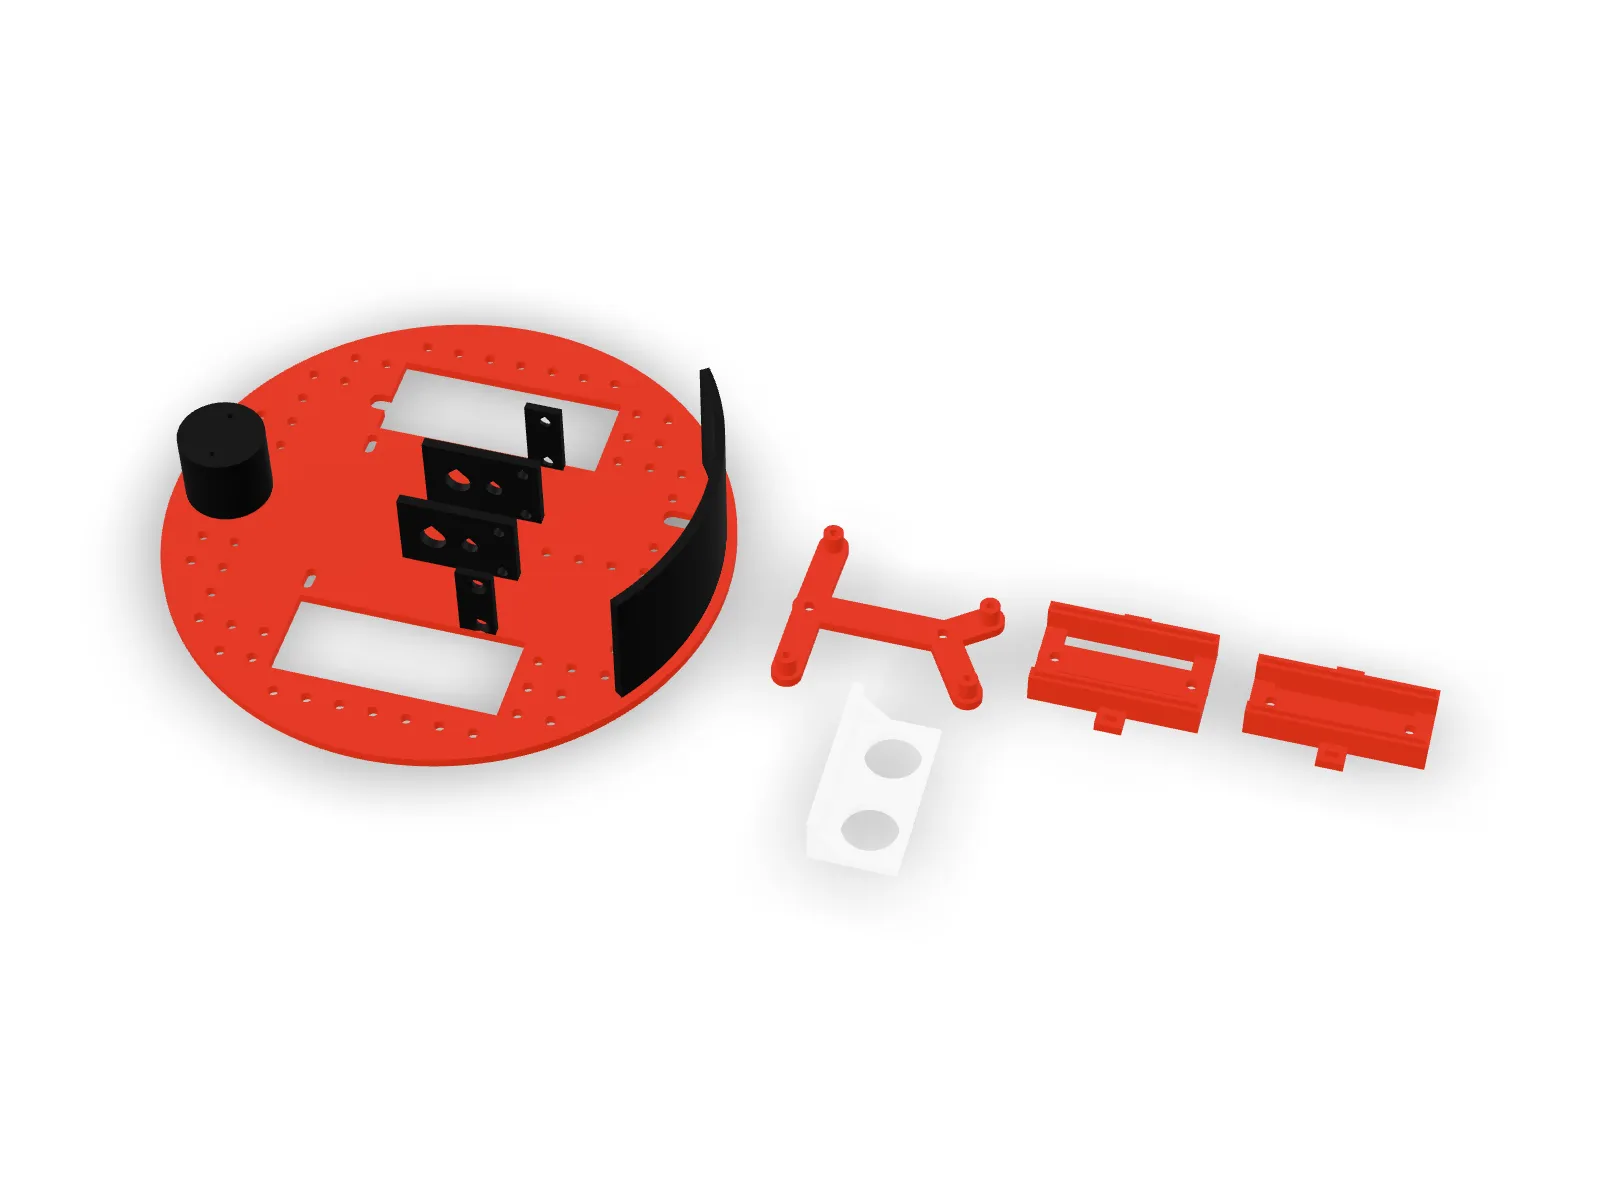
Round robot chassis
A two-wheel robot base that spins in place, with plates for an Arduino Uno, an ESP32 or a Pico.
- Deck diameter, the turning circle
- 170 mm
- Ground clearance under the battery
- 26 mm
- Print time
- 3.2 h on 3 plates
- Filament
- 106.1 g
Colourway
- Red main
- Black second
- Jade white accent
About the design
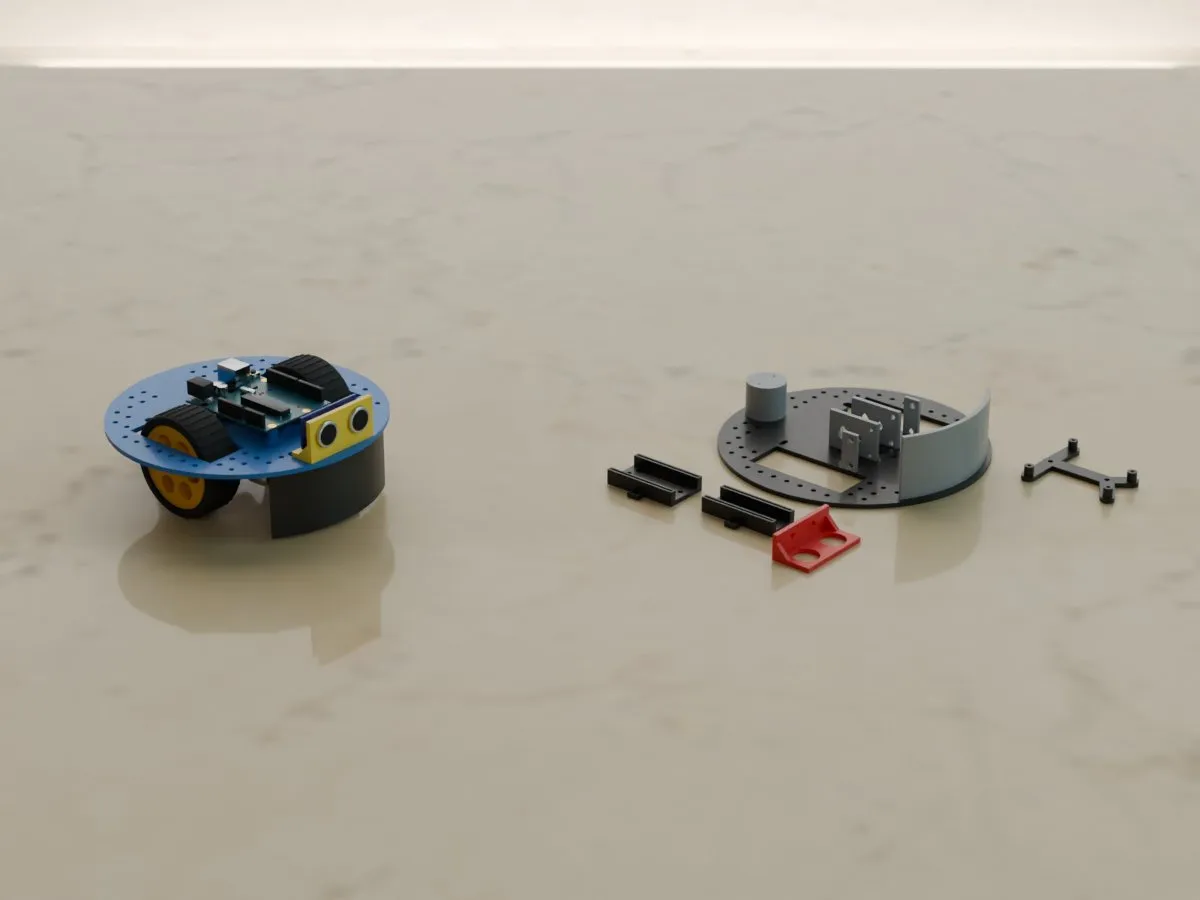
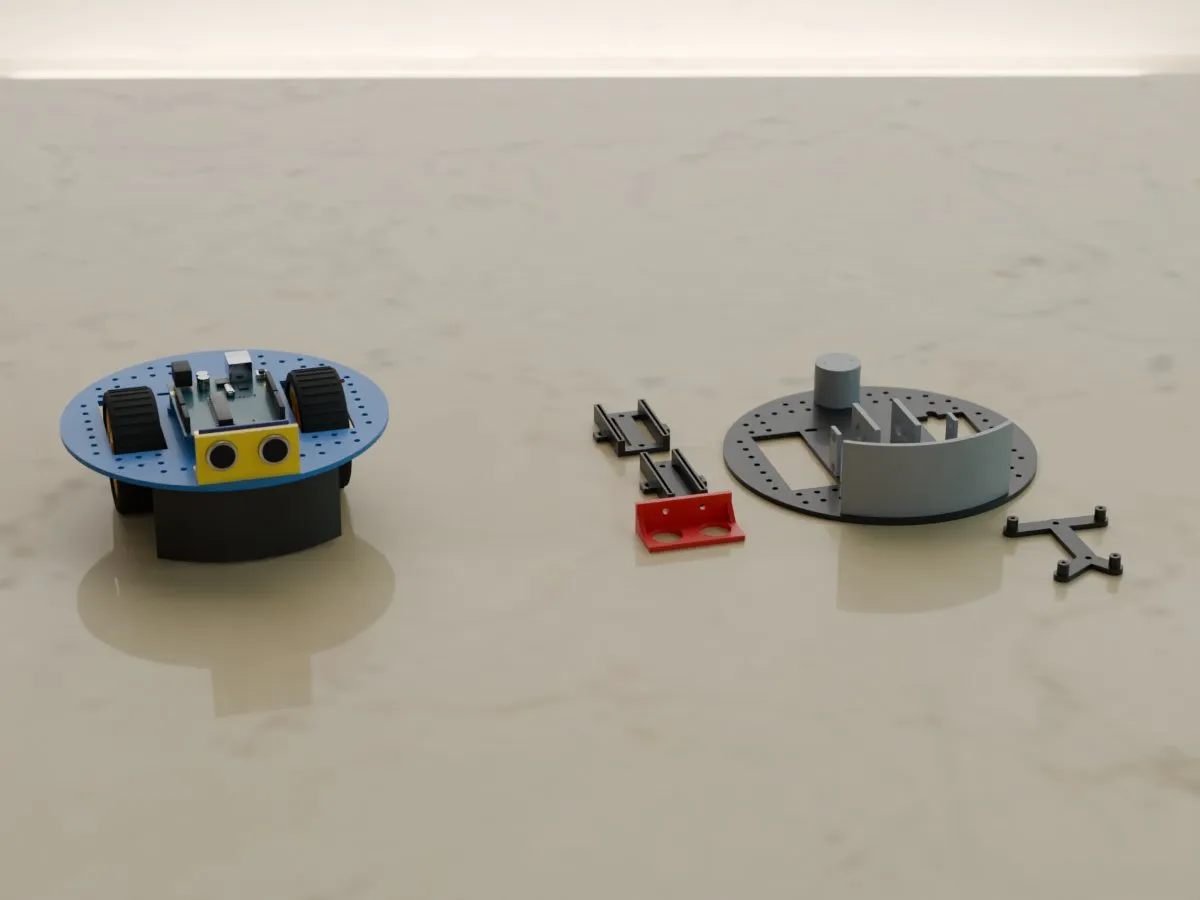
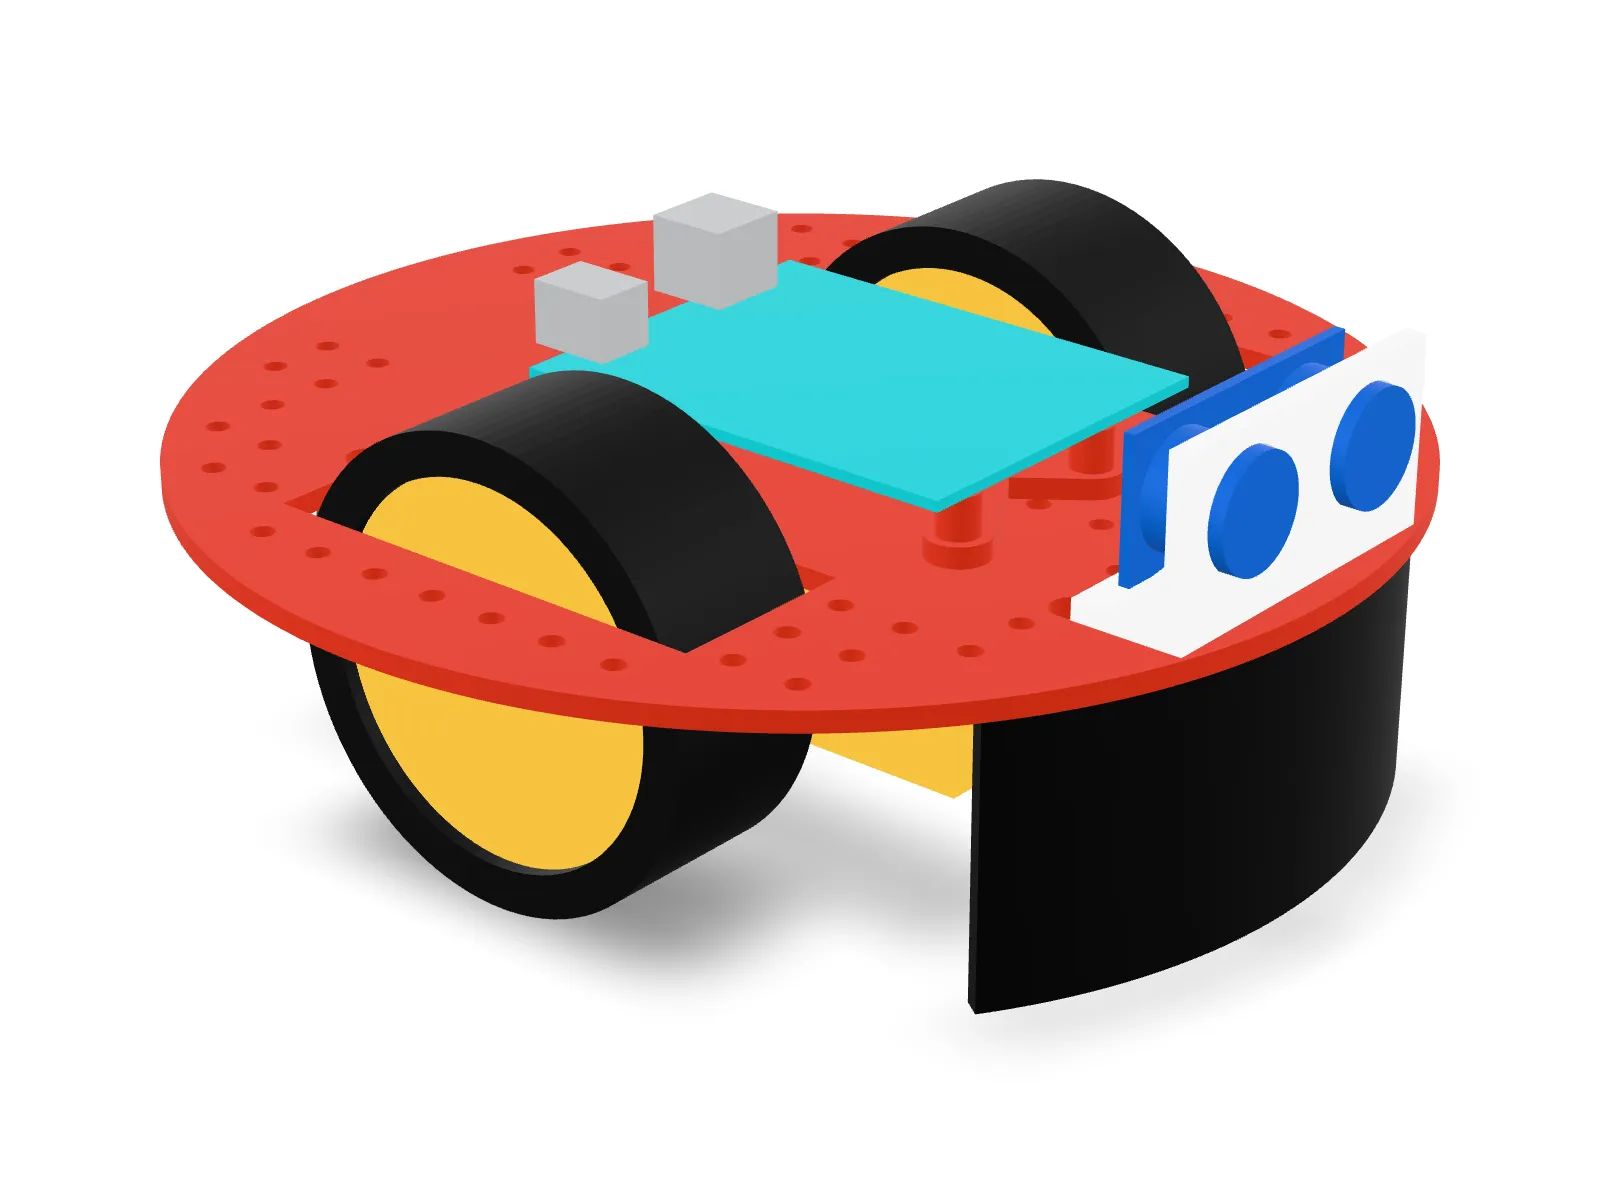
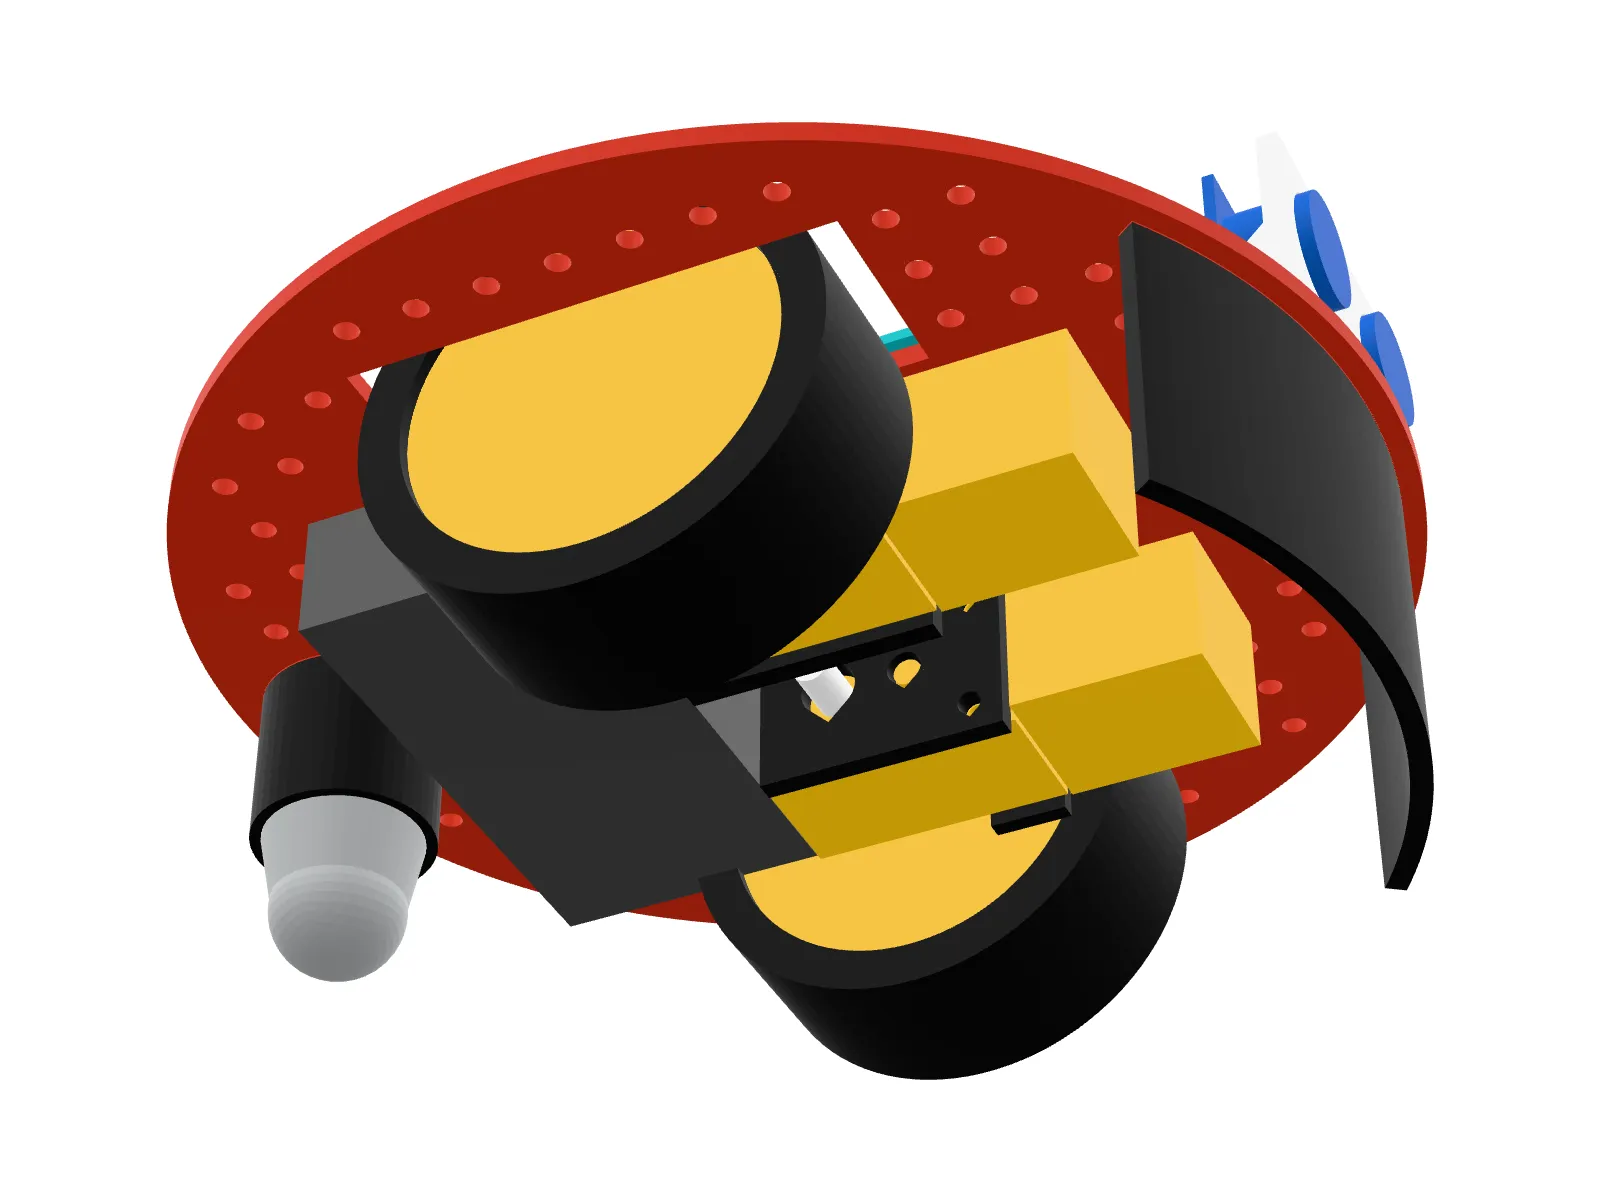
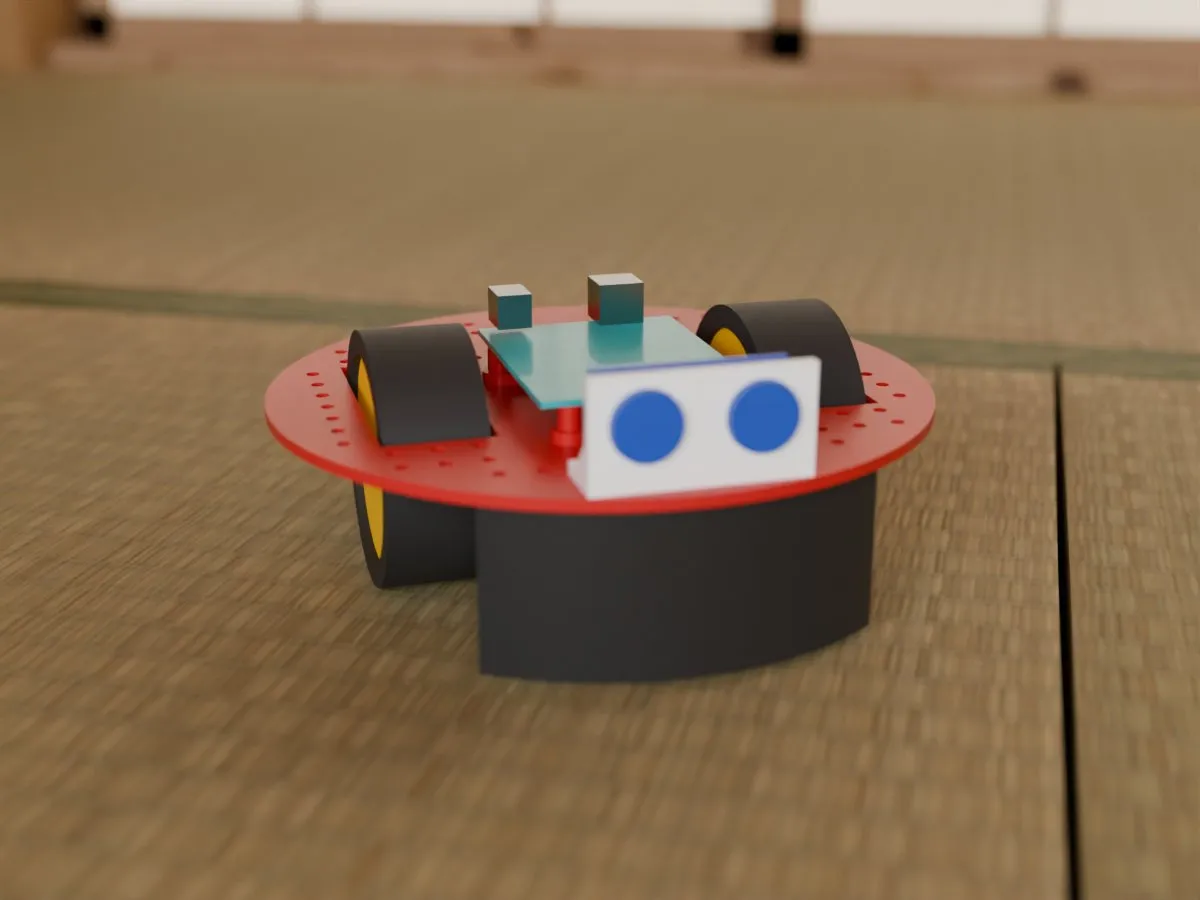
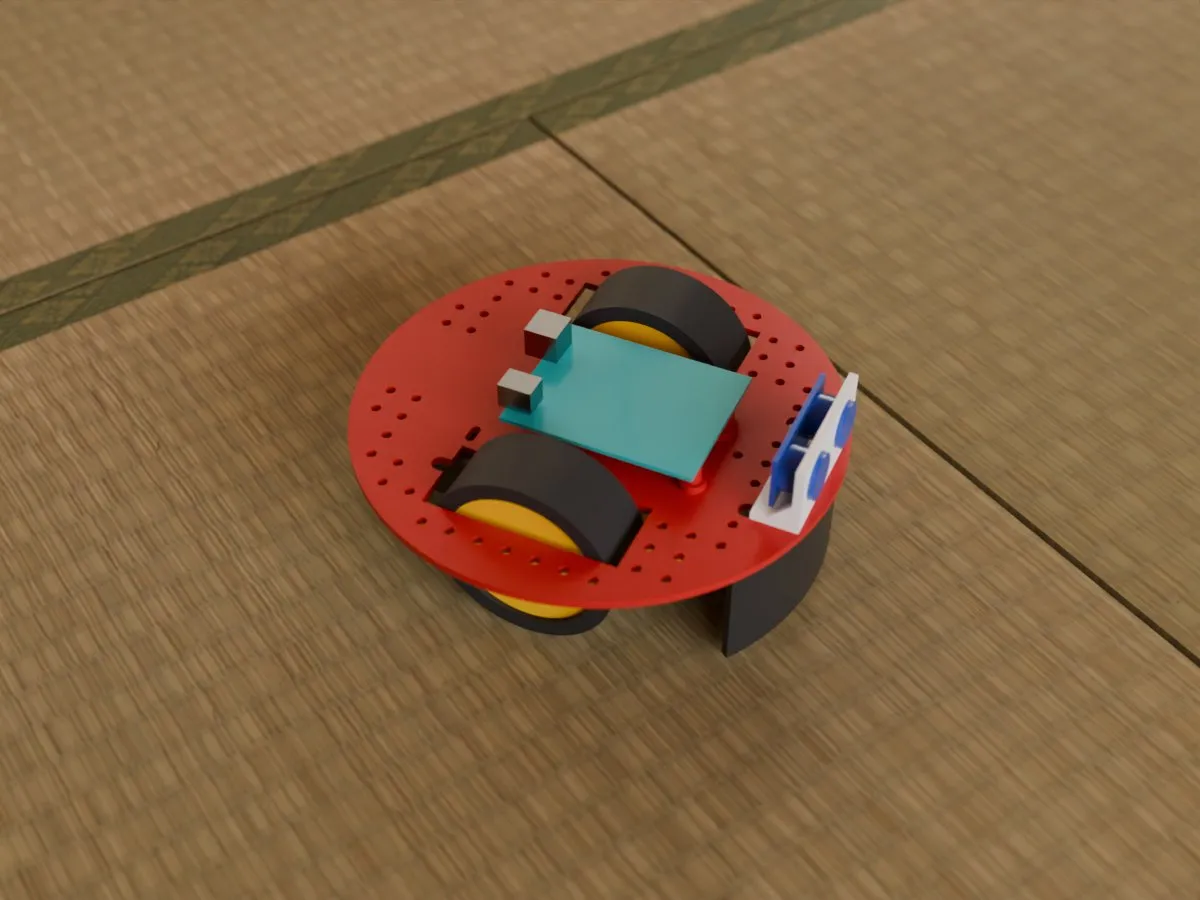
A round deck carries two TT gear motors, a 2 x 18650 battery pack and a ball caster underneath, with the wheels inside its circle on an axle through its centre, so the robot turns on the spot without its edge sweeping wider. Each motor is located by its own pin and clamped by two bolts, the battery hangs low between the axle and the caster for a stable stance, and a plate for the board and an HC-SR04 ranger bracket bolt to an M3 grid. The deck prints upside down in one piece with no supports.
What you can change
- Board (Uno R3, ESP32-DevKitC, Pico)
- Battery (2 x 18650 or 4 x AA)
- Motor hole position for your motor's clone
- Wheel and caster sizes
- Deck thickness and grid pitch
- Clearances round the wheels and motors
Specifications
- Deck diameter, the turning circle
- 170 mm
- Ground clearance under the battery
- 26 mm
- Robot mass with an Uno and 2 x 18650 cells
- 357 g
- Centre of gravity behind the axle
- 5.9 mm
Printing
| Project | Plates | Hours | Grams |
|---|---|---|---|
| Round robot chassis, PLA Basic | 3 | 3.2 | 106.1 |
| Total | 3 | 3.2 | 106.1 |
Times and weights come from the Bambu Studio 02.08.02.61 slice at 0.20 mm layers. Each figure is rounded on its own.
In the room
Credits and licence
The layout and the lessons of its users' comments come from xoxu's Robot arduino 3D print (https://www.thingiverse.com/thing:1582398, CC BY), and the round deck that spins in place from Pololu's Romi chassis. No file of either is used.
- Licence
- All rights reserved